Davide Malvezzi
PhD Student in Computer Science
Radar Perception • Sensor Fusion • Autonomous Racing
Radar Perception • Sensor Fusion • Autonomous Racing
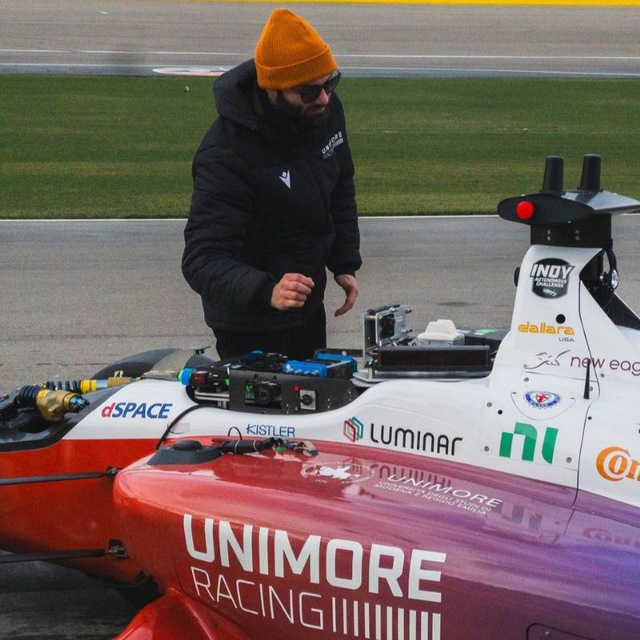
I am a PhD student at the University of Modena and Reggio Emilia working on radar perception, localization, and state estimation for autonomous vehicles. I develop perception and localization algorithms for autonomous vehicles, with a focus on object detection and tracking, optimization-based state estimation, and real-world autonomous racing. Prior to my doctoral studies, I worked as a Computer Vision Algorithm Engineer at VisLab (Ambarella Inc.) and held engineering roles at Datalogic and Eggtronic. I hold both a Bachelor's and Master's degree in Computer Science from UNIMORE.
Tightly Coupled Radar-Aided Grip Estimator For Autonomous Race Cars.
Doppler Refined ICP For Radar-Only Odometry.
High-Speed Real-Time Radar-Based Global Localization For Autonomous Racing.
Multi-Modal Perception Pipeline For Object Detection And Tracking In Autonomous Racing.
Email: davide.malvezzi@unimore.it